As automakers pursue different electrification strategies from electric vehicles (EVs) to hybrids (or a rollout of both), design engineers face the challenge of reducing the size and weight of electronic systems – specifically in traction inverters – to extend driving range and improve efficiency.
Traction inverters convert battery power to precisely control electric motor torque. Minor measurement errors of the motor-phase current can adversely impact the torque control loop, creating torque ripple: vibrations, uneven acceleration, unwanted noise, and inefficient operation that reduce driving range.
Traditional measurement approaches required choosing between traction inverter size, weight reduction and accuracy. The TMCS2100-Q1, the industry’s first multisensor, multiaxial Hall-effect current sensor, addresses current-measurement challenges without the need to compromise, a capability that’s increasingly critical as emerging 800V architectures push traction inverter accuracy requirements higher.
C-core to coreless: Solving one problem, creating another
Engineers historically measured the motor phase current in vehicles by using a C-core implementation, which consists of a linear ambient Hall-effect sensor placed in the air gap of a magnetic core that surrounds a conductor (Figure 1).
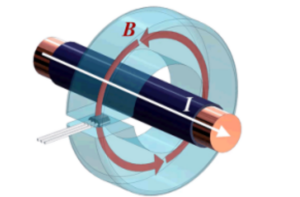
While eliminating magnetic crosstalk between the phases, a C-core adds considerable size and weight. With industry demand for smaller and lighter vehicles driving the adoption of coreless motor phase current measurements, designers must then address phase-to-phase crosstalk, displacement errors from vibration, and offset errors from external magnetic fields.
Displacement errors
Coreless current-sensing solutions do not measure current directly; they measure the magnetic field generated by current flowing through a conductor, as Ampere’s law describes. Since the magnitude of the magnetic field decreases as you move away from the conductor, you must “teach” a Hall-effect sensor the field strength that it will measure at its location relative to the conductor for a specific current value.
Once you teach the sensor the coupling factor of current to magnetic field, any displacement from this location point will result in a change in the magnetic field sensed for the same amount of current flowing through the conductor. This creates displacement errors.
Multiple factors contribute to displacement errors, including:
- Device-to-device variability of the Hall-effect sensor.
- Manufacturing tolerances of the mechanical parts of the assembly.
- Assembly tolerances.
- Vibration during operation of the vehicle.
End-of-line calibration can address most factors. However, vibration creates dynamic, random displacement errors that calibration cannot predict or correct.
The bus bar modification dilemma
Vibration is one of the major challenges in going coreless. The bus bar connects the traction inverter to the motor, while Hall-effect sensors are typically on a printed circuit board inside the traction inverter. Isolation requirements prevent the bus bar and sensor from being rigidly attached to each other, so vibration causes
relative movement between them – and that movement translates directly into measurement error. To combat this, manufacturers have developed several bus bar geometries, each balancing magnetic coupling strength against sensitivity to relative movement.
A differential coreless solution assesses vibration impact based on the change in magnetic field from the ideal point in space where end-of-line calibration occurs and displacement errors equal zero.
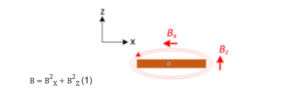
As Figure 2 demonstrates, engineers can calculate changes to the magnitude (|B|) of the specific magnetic field caused by the displacement of sensors with this understanding:
- The magnetic field magnitude decays 1/d from the conductor.
- The Hall-effect sensor is placed on the edge of the conductor to maximize field strength. • Differential magnetic fields minimize the impact of crosstalk.
- For z-axis displacement, the horizontal magnetic field (BX) decreases slower than the vertical magnetic field (BZ).
- For x-axis displacement, the horizontal magnetic field (BX) decreases faster than the vertical magnetic field (BZ).
- Typical vibration is 0.5mm to 0.7mm.
- Changes to |B| are directly equivalent to errors in the current measurement value. • Changes to |B| represent the root sum square of the individual axis errors (Equation 1):
B = B2X + B2Z (1)
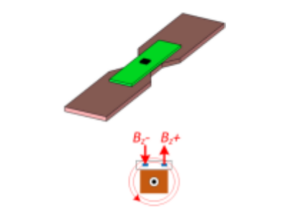
Three types of differential coreless sensors exist in the market. A vertical differential coreless sensor uses two opposite polarity sensors to measure the field in only the vertical direction and requires bus bar modifications so that its width matches the spacing of the sensors in the device (Figure 3).
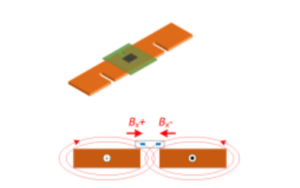
A horizontal differential coreless sensor uses two opposite polarity sensors to measure the field in only the horizontal direction and requires bus bar modifications with notches to create the proper magnetic field orientation for the sensors in the package (Figure 4).
SSZTDD7B – AUGUST 2026 – REVISED SEPTEMBER 2026 Submit Document Feedback
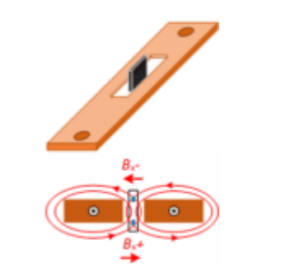
An in-hole differential coreless sensor measures only the horizontal field generated in a hole cut through the middle of the bus bar (Figure 5).
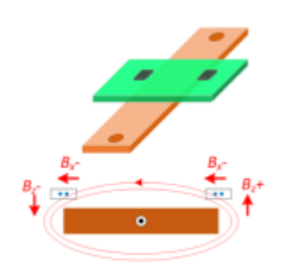
By using two devices relative to the bus bar, TI’s multisensor, multiaxial approach requires no bus bar modifications and simplifies the thermal management of hotspots that other coreless solutions typically generate (Figure 6). Each TMCS2100-Q1 device measures the field on its edge of the bus bar in both the horizontal and vertical directions, providing 100% of the magnetic field information for calculations. This full-field approach also minimizes the influence of magnetic crosstalk between phases, further protecting measurement accuracy, and reducing torque ripple.
Assuming a simple vibration model that causes movement of d = 0.4mm in the x-direction only, the z-direction only, or in both directions simultaneously (Table 1), you can calculate magnetic field changes measured by different implementations (Table 2).
Table 1. Vibration displacement definition
| (x – d, z + d) | (x, z + d) | (x + d, z + d) |
| (x – d, z) | Calibration point
(x, z) |
(x + d, z) |
| (x – d, z – d) | (x, z – d) | (x + d, z – d) |
Table 2. TMCS2100-Q1 delivers the lowest magnetic field error across coreless designs
| Vertical | Horizontal | In-hole | TMCS2100-Q1 | |
| Initial bus bar size (w × t) | 18mm-by-3mm | 18mm-by-3mm | 16mm-by-2mm | 18mm-by-3mm |
| Modifications to bus bar for sensor | 3.5mm-by-3mm
(notch to match sensor spacing in device) |
6mm-by-3mm
(3 slices – slice width to match sensor spacing in device) |
Hole:
10mm-by-5mm (bus bar thickness needs to match sensor spacing in device) |
None |
| Distance from bus bar | <2mm | <3mm | Inside bus bar | >3mm |
| Delta of |B| | BZ only | BX only | BX only | BX and BZ |
| Magnitude
error of magnetic field |
Most traction inverter systems require <3% of total error in all operating conditions. Many design engineers allocate a maximum 1% of vibration error, and would prefer less. As Table 2 shows, only the TMCS2100-Q1 achieves <1% performance for 0.4mm vibration in any direction, while competing solutions exceed the 3% total budget in most conditions. At smaller displacements, the TMCS2100-Q1’s advantage is even more pronounced when displacement error drops as low as 0.25% at 0.1mm of movement, roughly 20 times more accurate than single-axis coreless alternatives.
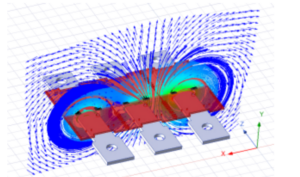
A multisensor, multiaxial approach to coreless differential current measurement minimizes vibration-induced errors while adapting to mechanical configurations without bus bar modifications, simplifying thermal design. Figure 7 shows a simulation of the magnetic field generated by the traction inverter current output to control the motor.
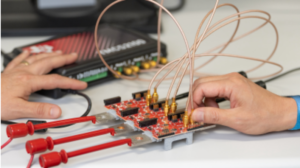
Designers can evaluate the performance of the device using the TMCS2100 evaluation module
(TMCS2100EVM). The module includes a 3D printed clip and a nickel-plated bus bar, and users can test up to three bus bars as shown in Figure 8. The evaluation module connects directly to the TMCS2100 characterization evaluation module (TMCS2100CHAREVM) to characterize the magnetic environment and calculate the coefficients to be programmed into each device.
Conclusion
Current-sensing accuracy improvements, combined with reduced complexity and lower costs, position this technology as a significant enabler for next-generation EV powertrains. As automakers push ahead for lighter, more efficient vehicles, a multiaxial approach demonstrates creative engineering.
The TMCS2100-Q1 multiaxial coreless Hall-effect current sensor measures magnetic fields in multiple directions simultaneously up to 20 times more accurately than single-axis alternatives – with <1% displacement error at 0.4mm movement (and as low as 0.25% at 0.1mm), dramatically reducing vibration impact while requiring zero bus bar modifications.

, design engineers face the challenge.)